ประกอบ Open Duck Mini v2: จาก STL ถึงเดินครั้งแรก

ชุด v2 มาตรฐานมี STL ต้นฉบับ 36 ไฟล์สำหรับพิมพ์ 51 ชิ้น เป็น PLA 49 และ TPU 2 ไม่ใช่ชุดพิมพ์ MicroDuck XL330 หรือ HD1910

ฉบับภาษาไทยเผยแพร่31ตุลาคม2026 วันที่เนื้อหาต้นฉบับแยกไว้ รุ่นเก่าไม่กลายเป็นข่าวใหม่เพราะปรับภาษา วันที่แก้เนื้อหา:

36 STL · 51 · PLA49 / TPU2

PLA15% ส่วน foot_bottom_tpu.stlเป็น TPU40% ลองเท้า/ข้อต่อก่อน layer supportและอุณหภูมิยังไม่มี presetครบ

36 STL · 51 · PLA49 / TPU2
STLต้นฉบับจำนวนวัสดุ / infill
foot_top.stl2PLA / 15%
foot_side.stl2PLA / 15%
foot_bottom_pla.stl2PLA / 15%
foot_bottom_tpu.stl2TPU / 40%
knee_to_ankle_left_sheet.stl4PLA / 15%
knee_to_ankle_right_sheet.stl4PLA / 15%
leg_spacer.stl4PLA / 15%
left_roll_to_pitch.stl1PLA / 15%
right_roll_to_pitch.stl1PLA / 15%
roll_motor_bottom.stl2PLA / 15%
roll_motor_top.stl2PLA / 15%
trunk_bottom.stl1PLA / 15%
trunk_top.stl1PLA / 15%
neck_left_sheet.stl1PLA / 15%
neck_right_sheet.stl1PLA / 15%
head_pitch_to_yaw.stl1PLA / 15%
head_yaw_to_roll.stl1PLA / 15%
head_roll_mount.stl1PLA / 15%
head.stl1PLA / 15%
head_bot_sheet.stl1PLA / 15%
left_antenna_holder.stl1PLA / 15%
right_antenna_holder.stl1PLA / 15%
left_cache.stl1PLA / 15%
right_cache.stl1PLA / 15%
body_front.stl1PLA / 15%
body_middle_bottom.stl1PLA / 15%
body_middle_top.stl1PLA / 15%
body_back.stl1PLA / 15%
battery_pack_lid.stl1PLA / 15%
bulb.stl1PLA / 15%
flash_light_module.stl1PLA / 15%
flash_reflector_interface.stl1PLA / 15%
left_eye.stl1PLA / 15%
right_eye.stl1PLA / 15%
speaker_interface.stl1PLA / 15%
speaker_stand.stl1PLA / 15%

1–2: BOM และพิมพ์

จับคู่ STS3215 7.4 V controller IMU และ bus adapter ตาม BOM ต้นฉบับกำหนด PLA infill 15% ยกเว้น foot_bottom_tpu.stl เป็น TPU 40% ยังไม่มี preset ครบเรื่อง layer support อุณหภูมิ ให้ลองเท้าและข้อต่อรับแรงก่อน

3–4: ID และโครง

ตั้งเซอร์โวทีละตัวตามตารางผู้เขียน ติดฉลาก ประกอบโดยตัดไฟ ตรวจ neutral ซ้าย/ขวา และความลึกสกรูเทียบภาพจริง

5–6: สายและระบบ

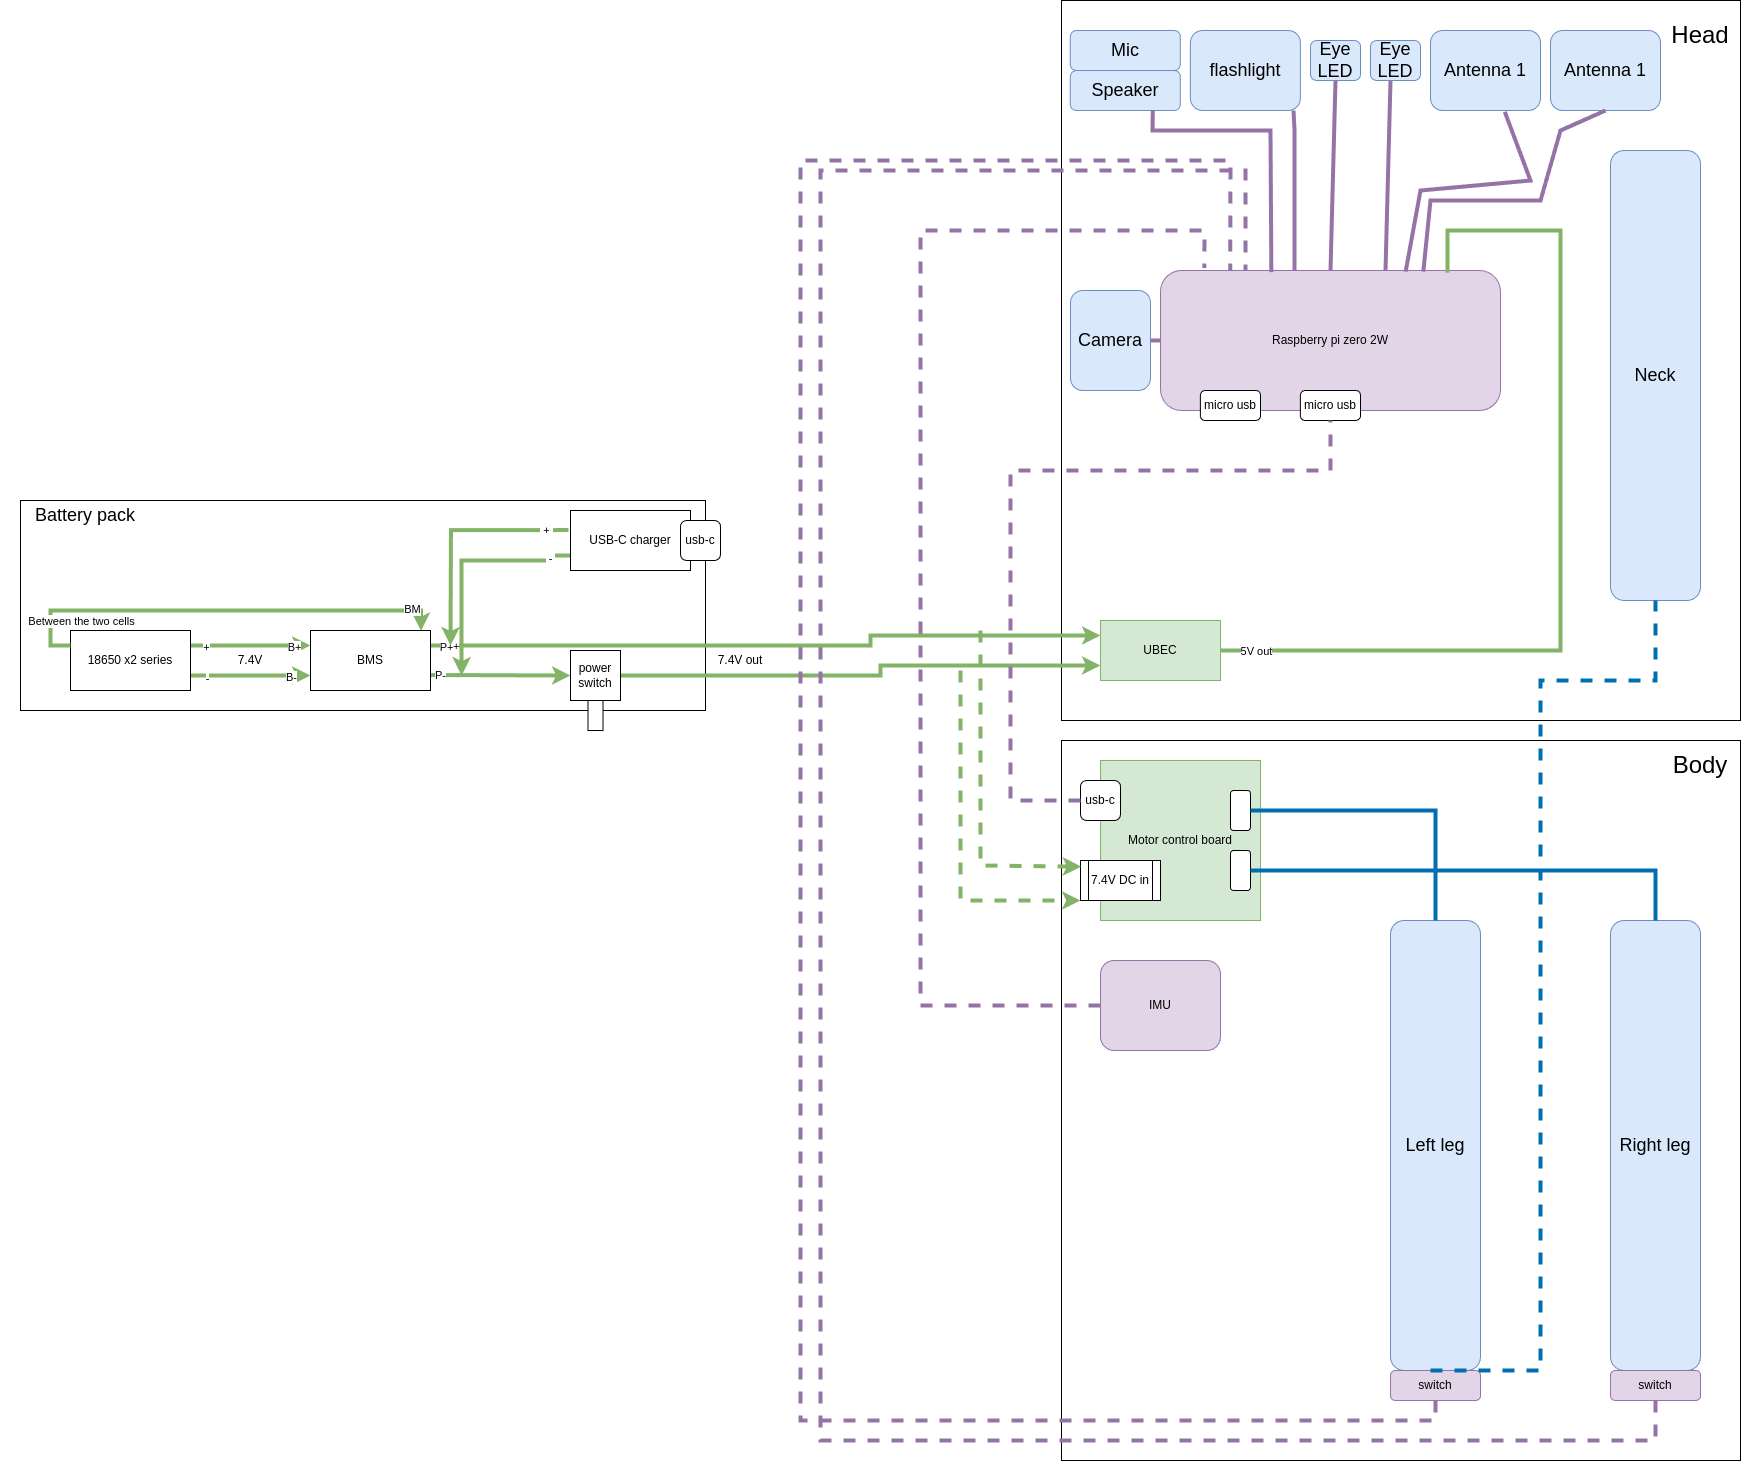
ตรวจขั้ว ground และสายบัสตามผัง Pi ใช้ regulator 5 V แยก ห้ามต่อแรงดันแบตเตอรี่ตรงขา 5 V ติดตั้ง runtime ของโครงการตาม revision แล้วตรวจ serial กับ sensor

7–8: ปรับเทียบและเดิน

ใช้ขั้นตอน runtime เดียวกันตรวจ zero ข้อต่อและทิศ IMU ลองสั้นโดยรองรับตัวและรู้วิธีหยุดก่อน ด้านล่างมีตารางไฟล์ ผังสาย และคู่มือออฟไลน์ เว็บไซต์ยังไม่พิมพ์ ทดสอบความพอดี หรือทดลองเดินจริง

คำสั่งของรุ่นต้นฉบับนี้

python scripts/configure_motor.py --help
python scripts/configure_motor.py --port /dev/ttyACM0 --id 20
git clone https://github.com/apirrone/Open_Duck_Mini_Runtime Open_Duck_Mini_Runtime-reviewed
cd Open_Duck_Mini_Runtime-reviewed
git checkout --detach 376de65435c93486347cd601a31aa96951799896
python v2_rl_walk_mujoco.py --onnx_model_path /absolute/path/BEST_WALK_ONNX_2.onnx

ผังสายต้นฉบับ

ผังสายต้นฉบับ · Open Duck Mini v2
Antoine Pirrone · Open Duck Mini v2 · Apache 2.0. Piใช้ regulator5 Vแยก ห้ามต่อไฟแบตเตอรี่ตรงขา5 V

ผังสายต้นฉบับ ↗ ↗

แหล่งข้อมูลและวันที่ตรวจ

ฉบับข้อมูลที่ตรวจ 9 กันยายน 2026 · ตรวจแหล่งข้อมูลแล้ว

  1. แหล่งข้อมูลต้นฉบับ 1 · github.com / README.md ↗
  2. แหล่งข้อมูลต้นฉบับ 2 · docs.google.com / edit ↗
  3. แหล่งข้อมูลต้นฉบับ 3 · tnkr.ai / open-duck-mini-v2 ↗
  4. แหล่งข้อมูลต้นฉบับ 4 · github.com / print_guide.md ↗
  5. แหล่งข้อมูลต้นฉบับ 5 · github.com / configure_motors.md ↗
  6. แหล่งข้อมูลต้นฉบับ 6 · github.com / configure_motor.py ↗
  7. แหล่งข้อมูลต้นฉบับ 7 · github.com / assembly_guide.md ↗
  8. แหล่งข้อมูลต้นฉบับ 8 · github.com / README.md ↗
  9. แหล่งข้อมูลต้นฉบับ 9 · github.com / INSTALL.md ↗
  10. แหล่งข้อมูลต้นฉบับ 10 · github.com / releases ↗
  11. แหล่งข้อมูลต้นฉบับ 11 · github.com / example_config.json ↗
  12. แหล่งข้อมูลต้นฉบับ 12 · github.com / check_motors.py ↗
  13. แหล่งข้อมูลต้นฉบับ 13 · github.com / checklist.md ↗
  14. แหล่งข้อมูลต้นฉบับ 14 · github.com / v2_rl_walk_mujoco.py ↗
  15. แหล่งข้อมูลต้นฉบับ 15 · github.com / sim2real.md ↗