हिंदी संस्करण 31 अक्टूबर 2026 को प्रकाशित। नीचे मूल सामग्री की तारीख अलग है; पुरानी रिलीज को नई घोषणा न मानें। मूल संशोधन:
Open Duck Mini v2 बनाना: प्रिंट से पहली चाल तक
मूल STL, 51 प्रिंटेड पुर्जे, wiring और अलग runtime का क्रम पढ़ें।
स्रोत और जाँच की तारीख
मूल मॉडल अपरिवर्तित, Apache 2.0; वास्तविक print,fit और walk साइट ने नहीं किए।
Commit b23317a485b3cec7d8417f352478778b3475173c
ZIP SHA-256 0d68bcf6650be56e26c40d463202a1c78980fc3e4f45258955eef1227beb3145
36 STL · 51 · PLA49 / TPU2
PLA 15%; foot_bottom_tpu.stl में TPU 40%। पहले पैर/जोड़ का fit test,layer/support/temperature स्वयं स्रोत से जांचें।
1–2: BOM और प्रिंट
मूल BOM के साथ 7.4 V STS3215, controller, IMU और bus adapter मिलाएं। मूल निर्देश PLA 15% infill और foot_bottom_tpu.stl के लिए TPU 40% बताते हैं। layer height, support और तापमान की सार्वभौम preset नहीं दी गई; पहले पैर और संरचनात्मक जोड़ का फिट नमूना बनाएं।
3–4: ID और असेंबली
हर सर्वो को अलग जोड़कर मूल ID तालिका लागू करें और label लगाएं। power बंद रखकर neutral alignment, बायां/दायां भाग और screw depth जांचें। लेखक के मूल चित्रों से हर जोड़ मिलाएं।
5–6: wiring और सिस्टम
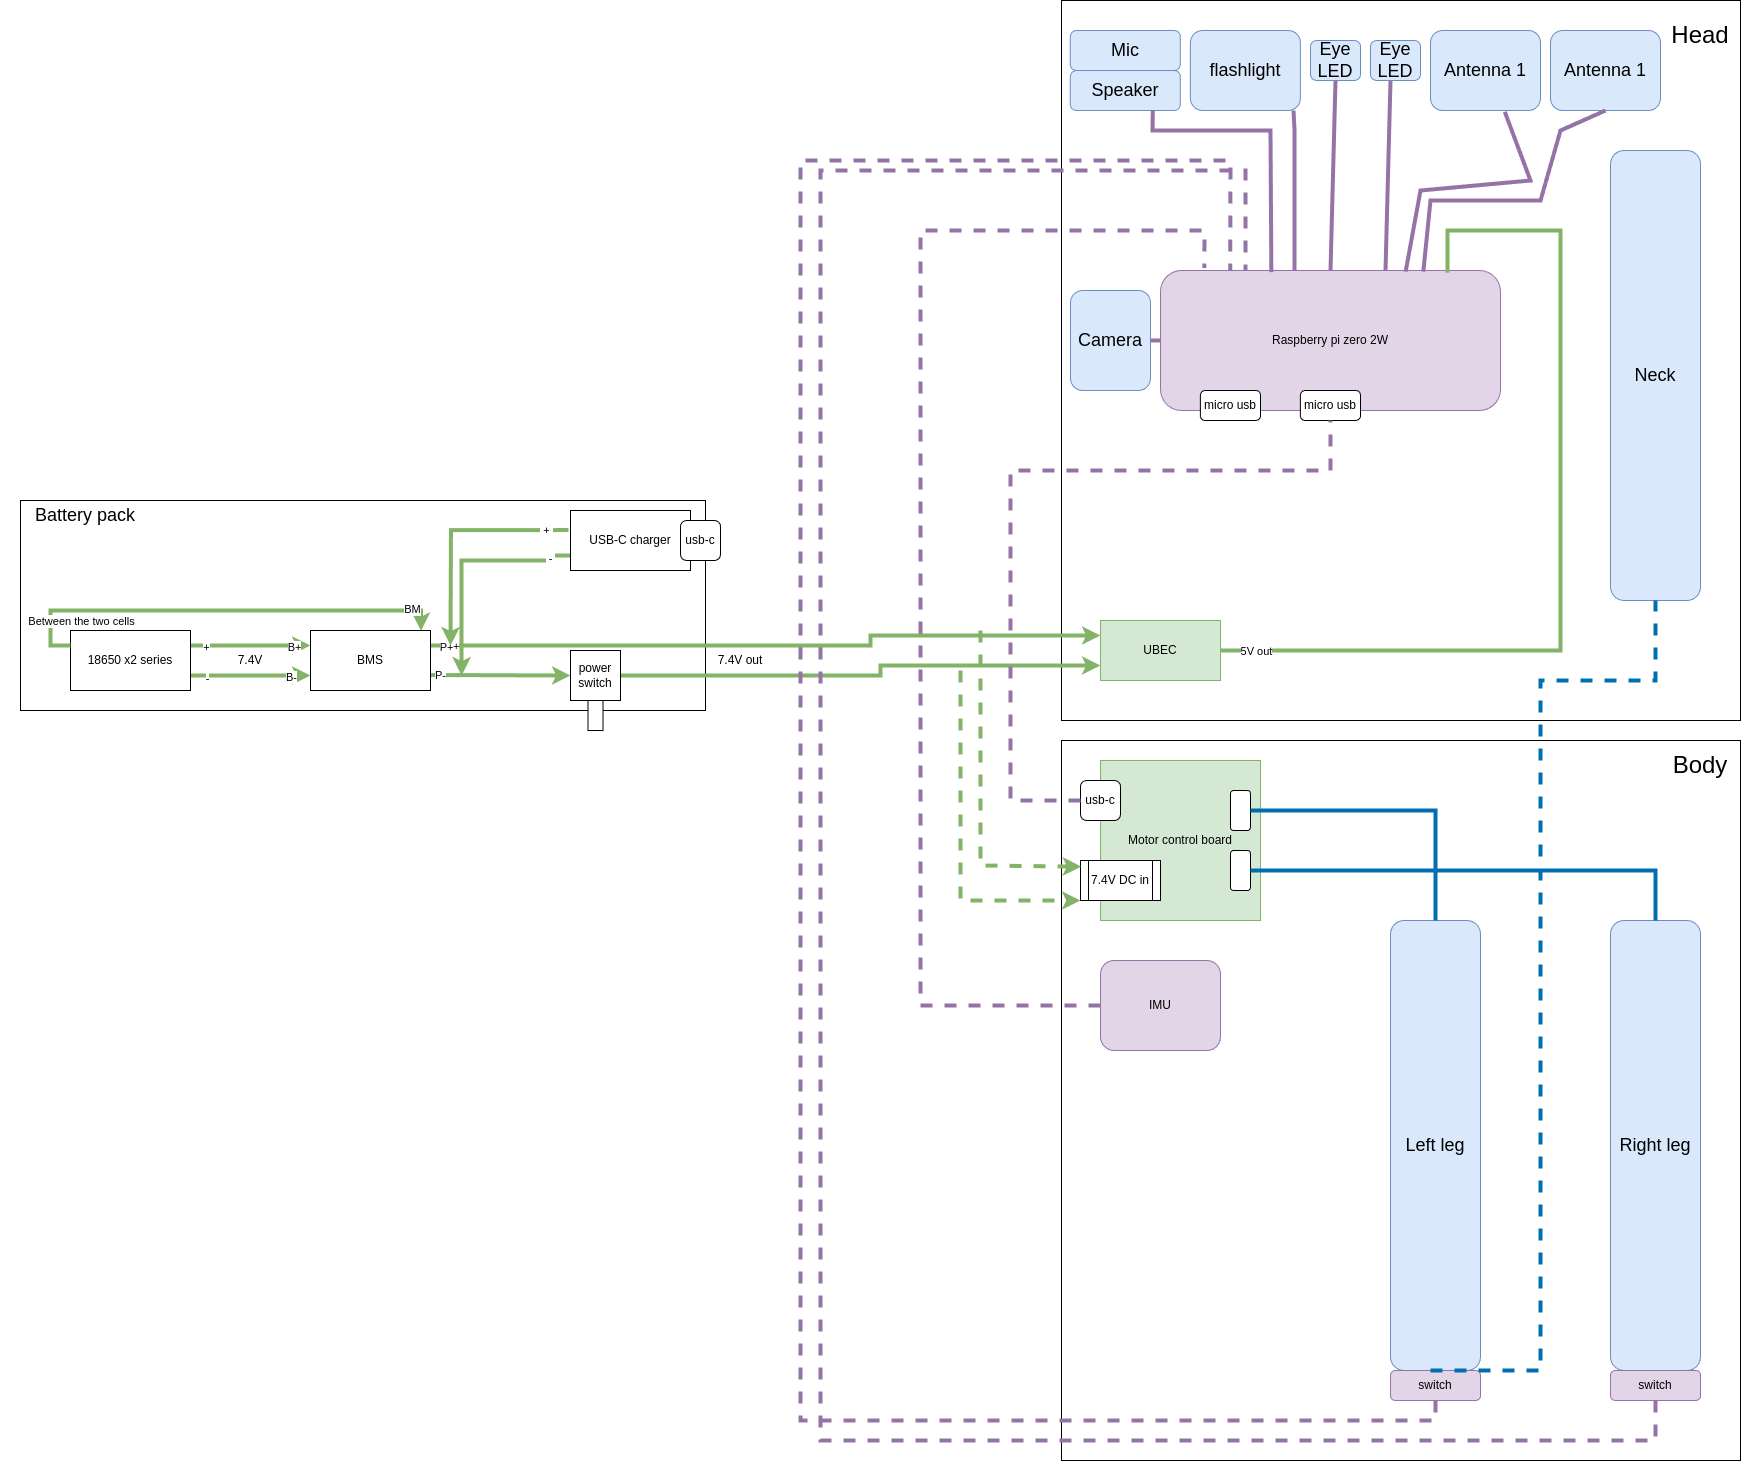
निर्दिष्ट wiring diagram से polarity, GND और bus chain जांचें। Pi को अलग regulated 5 V दें, battery rail सीधे 5 V pin में न लगाएं। केवल इसी परियोजना का runtime और fixed revision स्थापित करें; पहले serial और sensor जांचें।
7–8: calibration और पहली चाल
उसी runtime की calibration प्रक्रिया से joint zeros और IMU orientation जांचें। समर्थन के साथ छोटा test करें, पहले रुकना सीखें और unexpected movement पर आगे न बढ़ें। नीचे पूरी मूल फाइल सूची, wiring diagrams और offline guide हैं; साइट ने वास्तविक प्रिंट/फिट/चाल नहीं जांची है।
स्रोत के संस्करण से संबंधित कमांड
python scripts/configure_motor.py --helppython scripts/configure_motor.py --port /dev/ttyACM0 --id 20git clone https://github.com/apirrone/Open_Duck_Mini_Runtime Open_Duck_Mini_Runtime-reviewed
cd Open_Duck_Mini_Runtime-reviewed
git checkout --detach 376de65435c93486347cd601a31aa96951799896python v2_rl_walk_mujoco.py --onnx_model_path /absolute/path/BEST_WALK_ONNX_2.onnxमूल wiring diagram
स्रोत और जाँच की तारीख
स्रोत का संस्करण 9 सितंबर 2026 · स्रोत की जाँच हुई
- मूल स्रोत 1 · github.com / README.md ↗
- मूल स्रोत 2 · docs.google.com / edit ↗
- मूल स्रोत 3 · tnkr.ai / open-duck-mini-v2 ↗
- मूल स्रोत 4 · github.com / print_guide.md ↗
- मूल स्रोत 5 · github.com / configure_motors.md ↗
- मूल स्रोत 6 · github.com / configure_motor.py ↗
- मूल स्रोत 7 · github.com / assembly_guide.md ↗
- मूल स्रोत 8 · github.com / README.md ↗
- मूल स्रोत 9 · github.com / INSTALL.md ↗
- मूल स्रोत 10 · github.com / releases ↗
- मूल स्रोत 11 · github.com / example_config.json ↗
- मूल स्रोत 12 · github.com / check_motors.py ↗
- मूल स्रोत 13 · github.com / checklist.md ↗
- मूल स्रोत 14 · github.com / v2_rl_walk_mujoco.py ↗
- मूल स्रोत 15 · github.com / sim2real.md ↗